A Gwaihir Robotics company Richmond, Virginia Coming soon

The American
actuator kit.

A reference design for brushless actuators. US-made stators and machined housings in the box. Bring your own drivers, magnets and gearing.
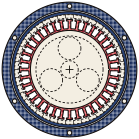
Top-down section of the RD-81 frame: housing and rotor can around an 81 mm, 36-slot stator, with the magnet ring and planetary gearing drawn dashed
RD-81 · 81.0 mm stator · 36 slots
Dashed = you bring it
1The
kit

Stators and housings. Nothing else.

The hard-to-source half of a brushless actuator, made in America: the silicon-steel stator and the machined frame that holds it true. The half where your design lives stays yours.

In the box
  • A Stator stack Bonded silicon-steel laminations from American Stator. Real production profiles, 43 to 100 mm.
  • B Housing set Machined rear cap, rotor can and output housing. Bearing seats, bolt pattern and stator carrier sized to the stack.
You bring
  • C Driver Your controller, your firmware, your bus voltage.
  • D Magnets Your grade, your pole count, your supplier. The rotor can is ready for them.
  • E Gearing Direct drive, planetary in the stator bore, cycloidal or harmonic. Your ratio.

Fig. 01 — Exploded view, reference actuator

RD · Side elevation Not to scale Exploded side view of the reference actuator, top to bottom: your driver board, rear cap, stator stack, rotor can with your magnets, your gearing, output housing. Kit parts are solid; bring-your-own parts are dashed. 1 2 3 4 5 6
  1. 1
    Driver boardYou bring
    Mounts to the rear cap. Encoder and sensor space on the centreline.
  2. 2
    Rear capIn the box
    Carries the stator and the rear bearing. Driver bolt pattern on the back face.
  3. 3
    Stator stackIn the box
    Bonded silicon-steel laminations. Its bore is open for gearing.
  4. 4
    Rotor can · magnetsCan in box · magnets you bring
    The can is machined to the stack. Your magnets bond to its inner wall.
  5. 5
    GearingYou bring
    Planetary, cycloidal, harmonic, or none at all.
  6. 6
    Output housingIn the box
    Output bearing seat and mounting flange.
2Bring
your own

Your stack. Your call.

Every actuator team already has opinions about its driver, its magnets and its ratio. That's where the IP lives. We don't touch it.

What teams can't easily get is a domestic stator and a frame that holds it concentric to the rotor. That's the part of the motor that comes from overseas today, and it's the part we put in the box.

Fig. 02 — Who supplies what

C DriverYouYour firmware, your FOC tuning, your bus voltage, your comms
D MagnetsYouYour grade, your pole count, your supplier
E GearingYouDirect drive to high-ratio, set by your joint
A+B Stator + housingUS BLDCMade in America. The part nobody else stocks.
3Frames

Four frames. Real stator profiles.

Each frame is built around a production lamination from the American Stator catalog.

RD-43 Rev A RD-43 frame section: 43 mm, 24-slot stator in its housing
RD-43 · 24-slot
43mm
Compact joints, gimbals and small-arm wrists.
Stator OD
43.3 mm
Slots
24
RD-60 Rev A RD-60 frame section: 60 mm, 24-slot stator in its housing
RD-60 · 24-slot
60mm
Mid-size robot joints and UAS payload actuators.
Stator OD
60.0 mm
Slots
24
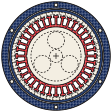
RD-81 Rev A RD-81 frame section: 81 mm, 36-slot stator in its housing
RD-81 · 36-slot
81mm
Quasi-direct-drive class. Humanoid knees, elbows and legged robots.
Stator OD
81.0 mm
Slots
36
RD-100 Rev A RD-100 frame section: 100 mm, 36-slot stator in its housing
RD-100 · 36-slot
100mm
Humanoid hips and shoulders, cobot base joints.
Stator OD
100.0 mm
Slots
36
4Reference

A reference, not a black box.

Every frame ships as a documented design you can build on: defined interfaces for the parts you bring, and drawings for the parts we make.

Stator bore
You bringOpen for gearing: a planetary can sit inside the stator
Rotor can
You bringInner wall machined as a seat for your magnets
Rear cap
You bringDriver and encoder mount on the back face
Output
Output bearing seat and mounting flange
Stack height
Set with pilot partners
Files
Drawings and CAD published at launch
Build the motor. Skip the import.
5For

Teams who build their own joints.

01 — Robotics
Humanoid + legged
Actuator teams who want a domestic motor core under their own driver and gearbox.
02 — Drone
UAS payloads
Gimbals, winches and control surfaces on platforms that need a US-sourced bill of materials.
03 — Defense
Prototype programs
Ground and air actuator prototypes working toward a domestic-supply requirement.
04 — Labs
Universities + R&D
A known-good motor frame to iterate drivers, control and gearing against.
6Waitlist

Get the first kits.

Kits are coming soon. Tell us what you're building and which frame you need, and we'll write when they ship.

Made in America.
Finished by you.